I am Tianxin Hu, recently graduated with an M.Sc. in Computer Control and Automation from Nanyang Technological University (NTU), Singapore, under the supervision of Prof. Lihua Xie. My background is in optimization-based planning and control for autonomous systems, with practical experience in ROS/ROS2, C++/Python, and simulation-driven validation.
I am currently transitioning toward reinforcement learning for robot locomotion, with ongoing work spanning quadruped locomotion and humanoid control. More broadly, I am interested in integrating structured dynamical priors into learning-based control to achieve robust, interpretable, and natural robot locomotion. Selected ongoing work is listed below under Ongoing Explorations.
💼 Current Position
- Jun 2026 – Present, Nanyang Technological University (NTU), Singapore
Research Assistant, Prof. Lihua Xie’s Group
Working on a humanoid robotics project with Chery Robotics, focusing on reinforcement learning for humanoid locomotion in embodied task execution scenarios.
📖 Education
-
Aug 2024 – Jan 2026, Nanyang Technological University, Singapore
M.Sc. in Computer Control and Automation, School of Electrical and Electronic Engineering
GPA: 95/100 -
Sep 2020 – Jun 2024, Wuhan University of Science and Technology, China
B.Eng. in Vehicle Engineering (Industrial Planning), School of Automobile and Traffic Engineering
GPA: 88.3/100
📝 Publications
✅ Accepted & Published
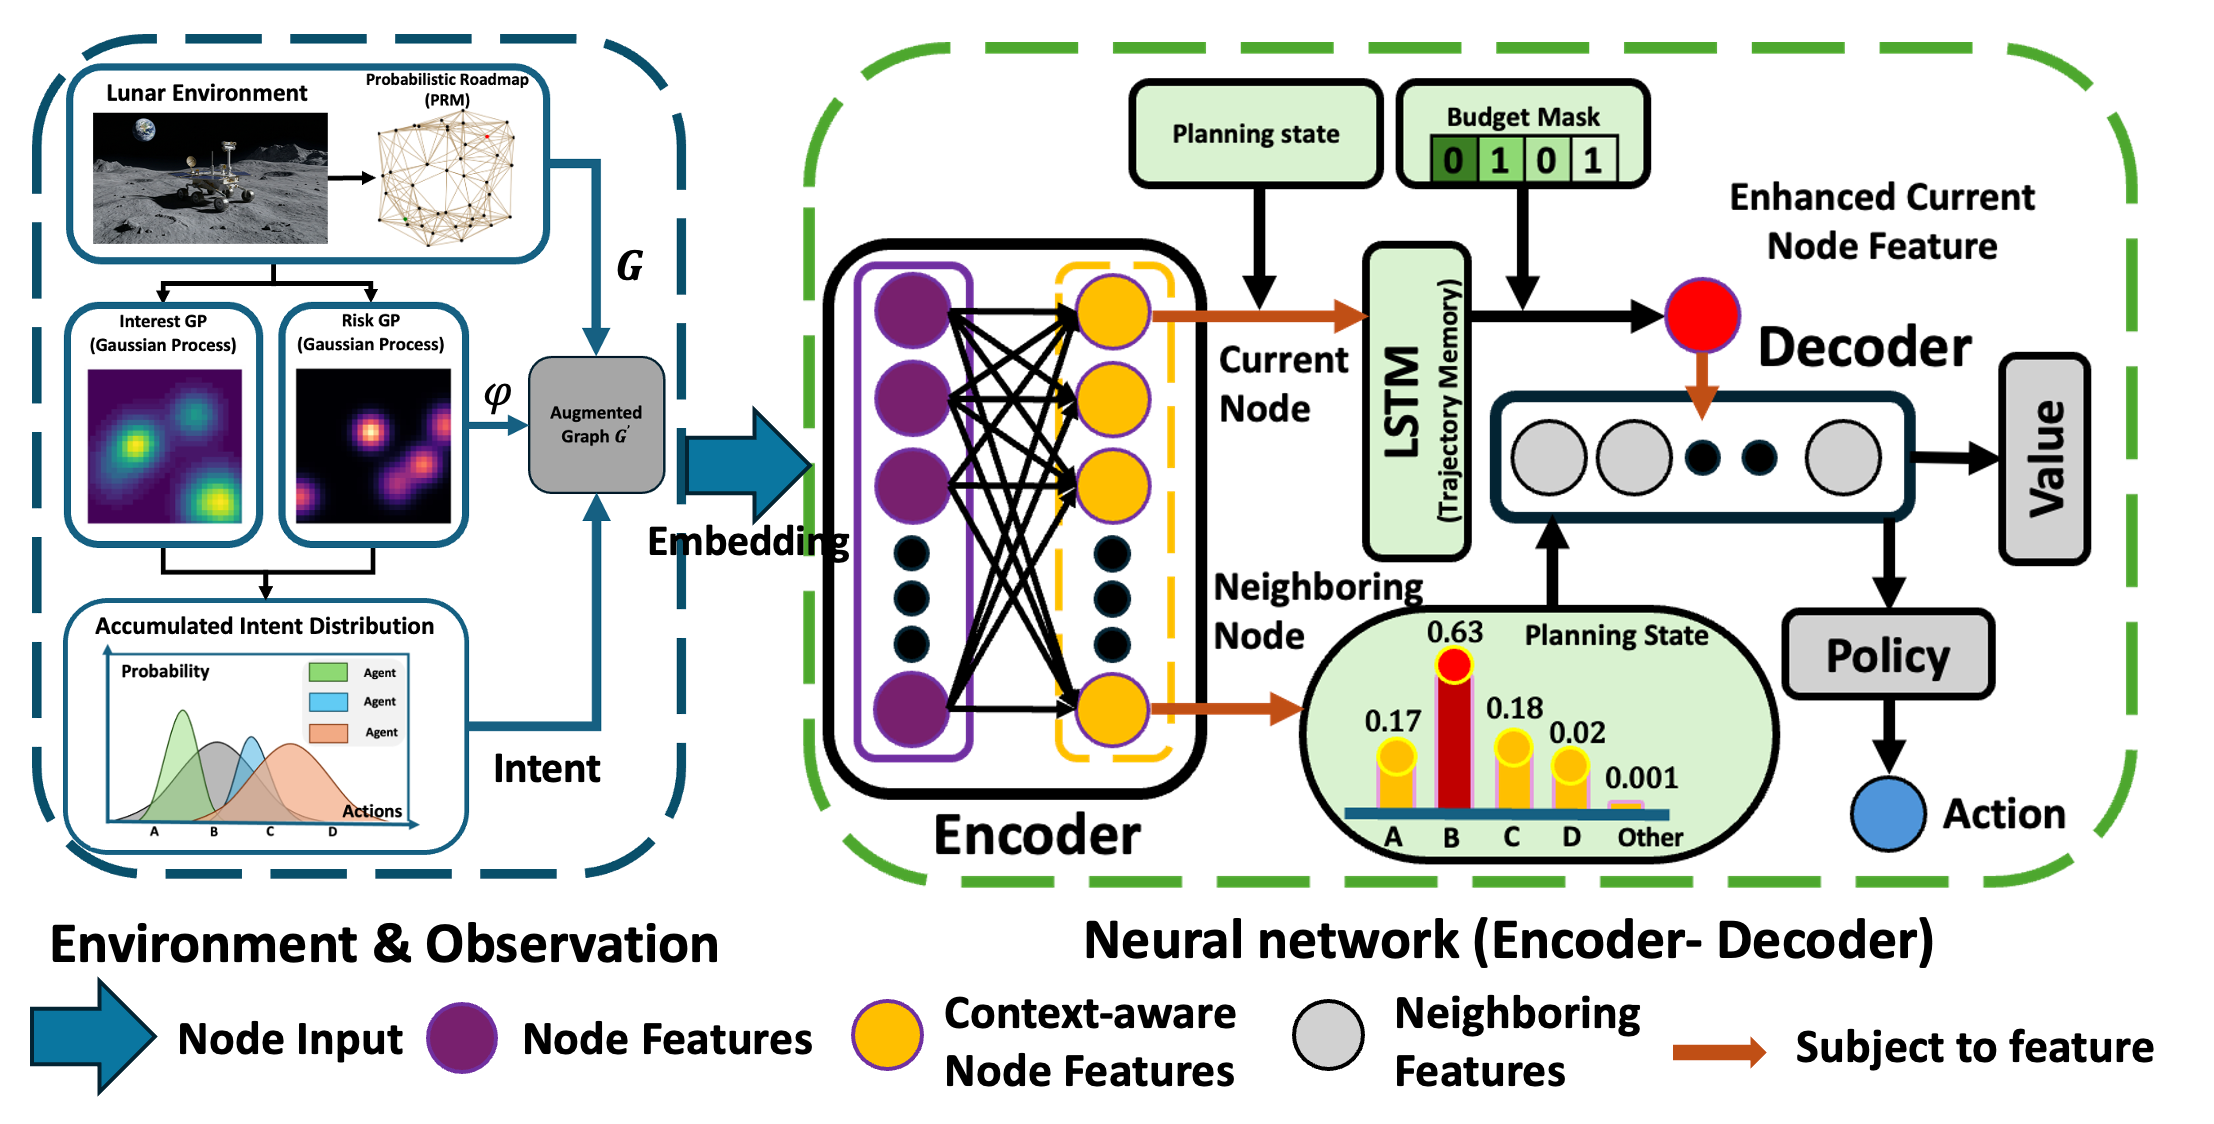
Multi-Agent Off-World Exploration for Sparse Evidence Discovery via Gaussian Belief Mapping and Dual-Domain Coverage
Accepted by IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) , September 2026
Co-author
Zhuoran Qiao, Tianxin Hu, Thien-Minh Nguyen, Shenghai Yuan
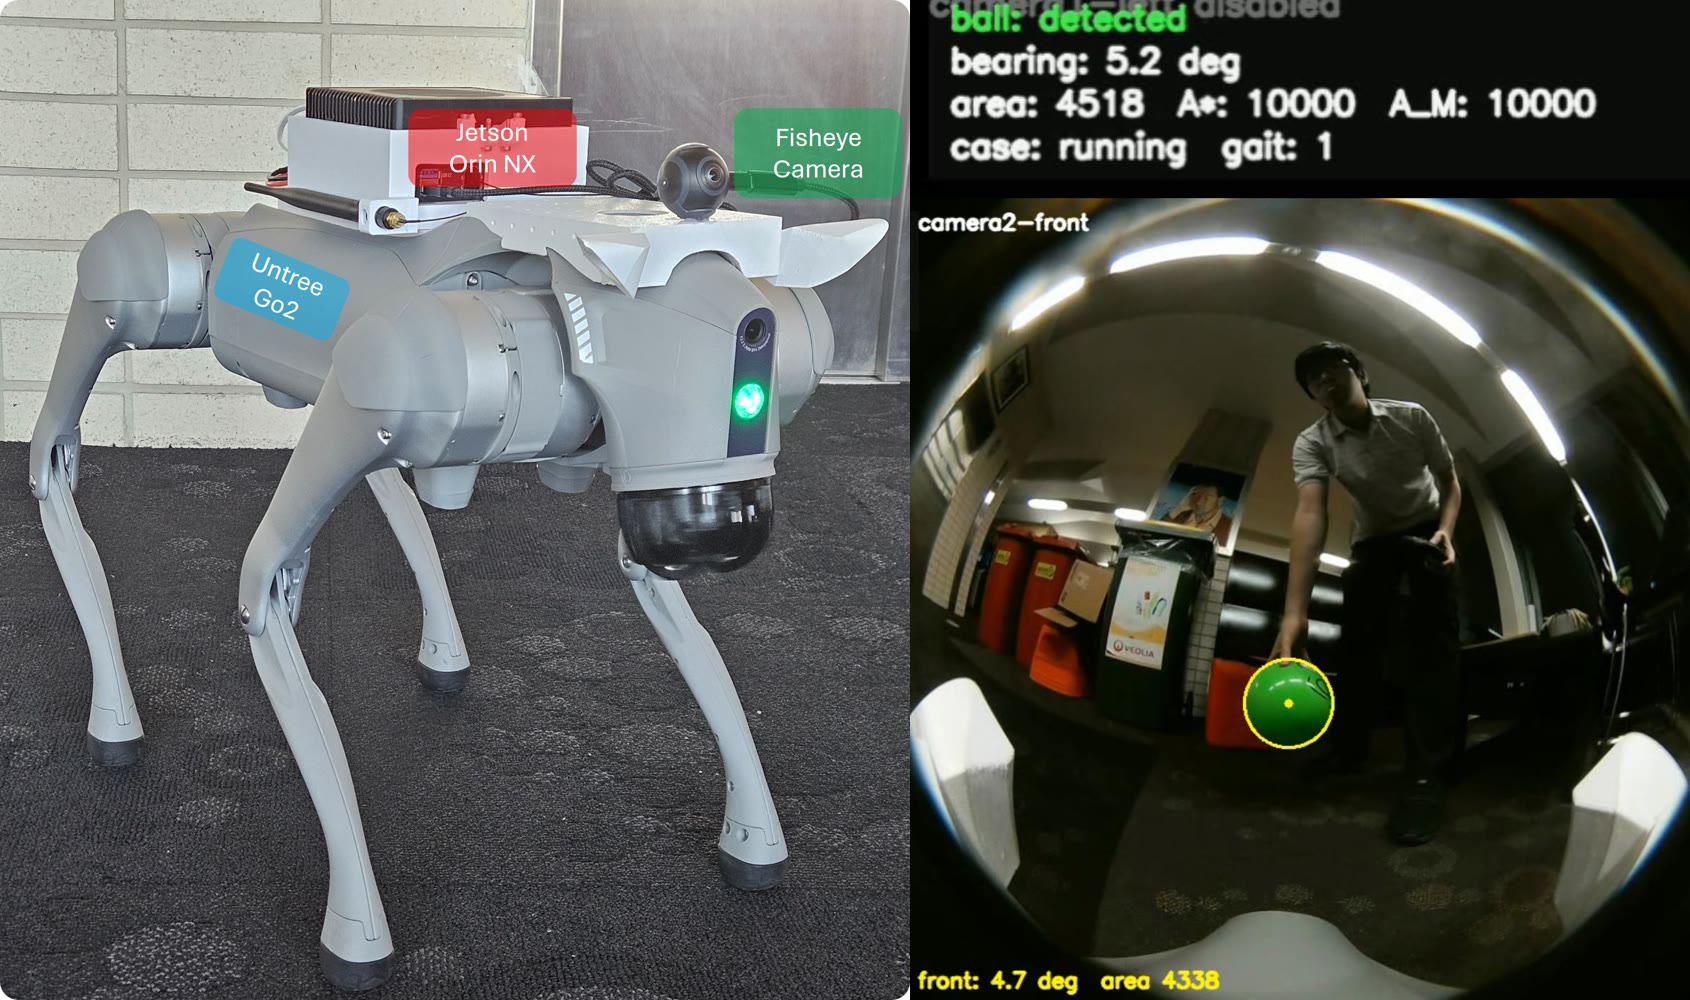
Interactive Object Tracking on Gait-Parameterized Locomotion Policy
Accepted as an oral presentation at the International Conference on Control, Automation, Robotics and Vision (ICARCV) , November 2026
Co-author
Gia-Hung Huynh, Tianxin Hu, Tien-Dat Nguyen, Shenghai Yuan, Thien-Minh Nguyen
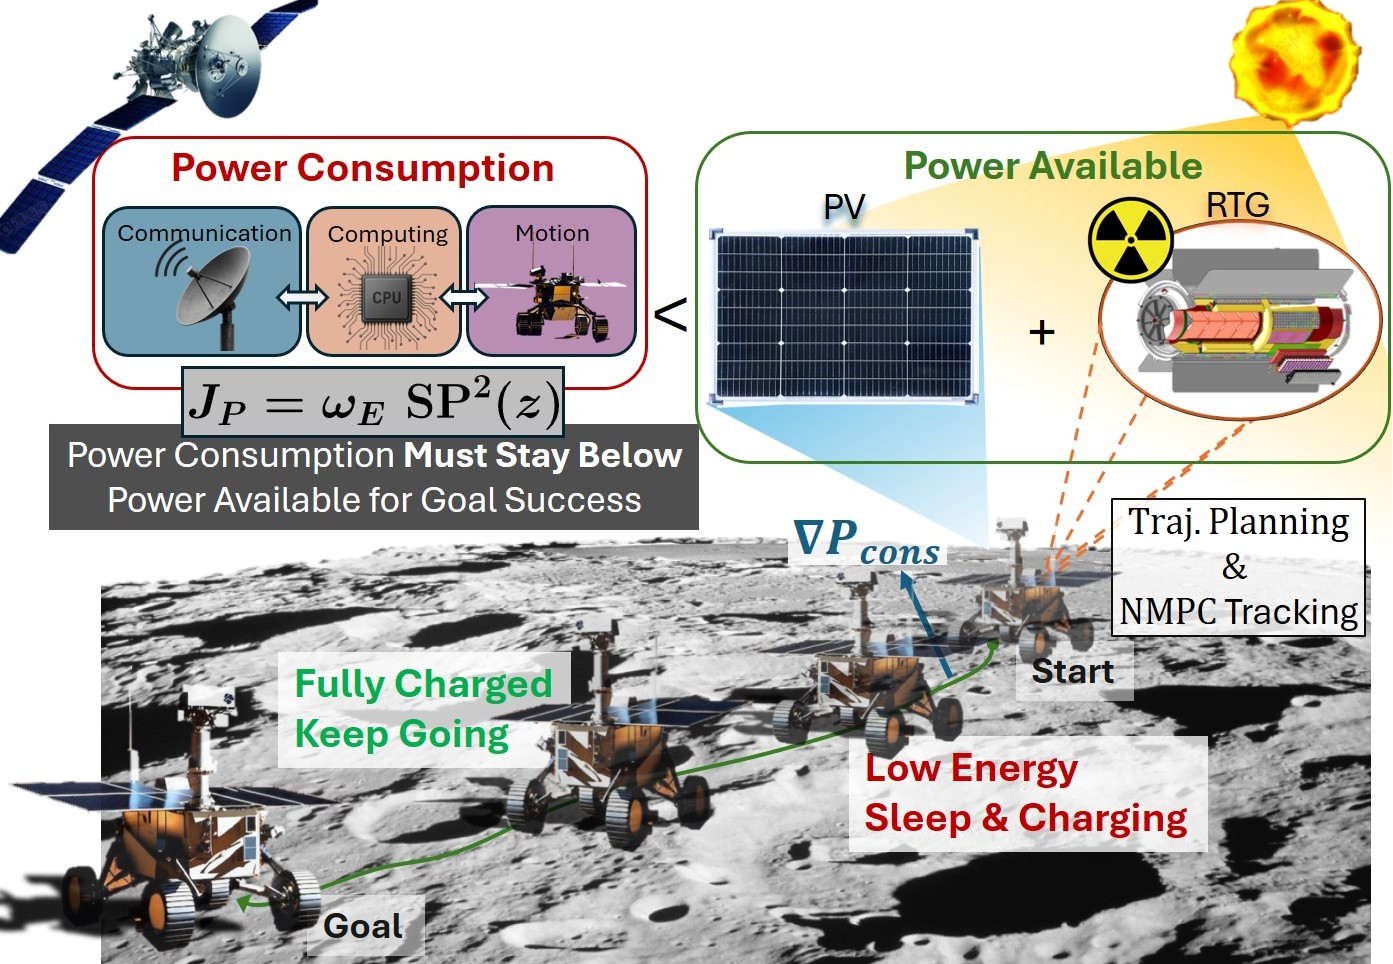
Energy-Constrained Navigation for Planetary Rovers With Singular Internal Power Source
Accepted as an oral presentation at the IEEE International Conference on Control & Automation (ICCA), April 2026
Tianxin Hu*, Weixiang Guo*, Rui Qian, Jiaye Jin, Haoran Zhao, Shenghai Yuan, Lihua Xie
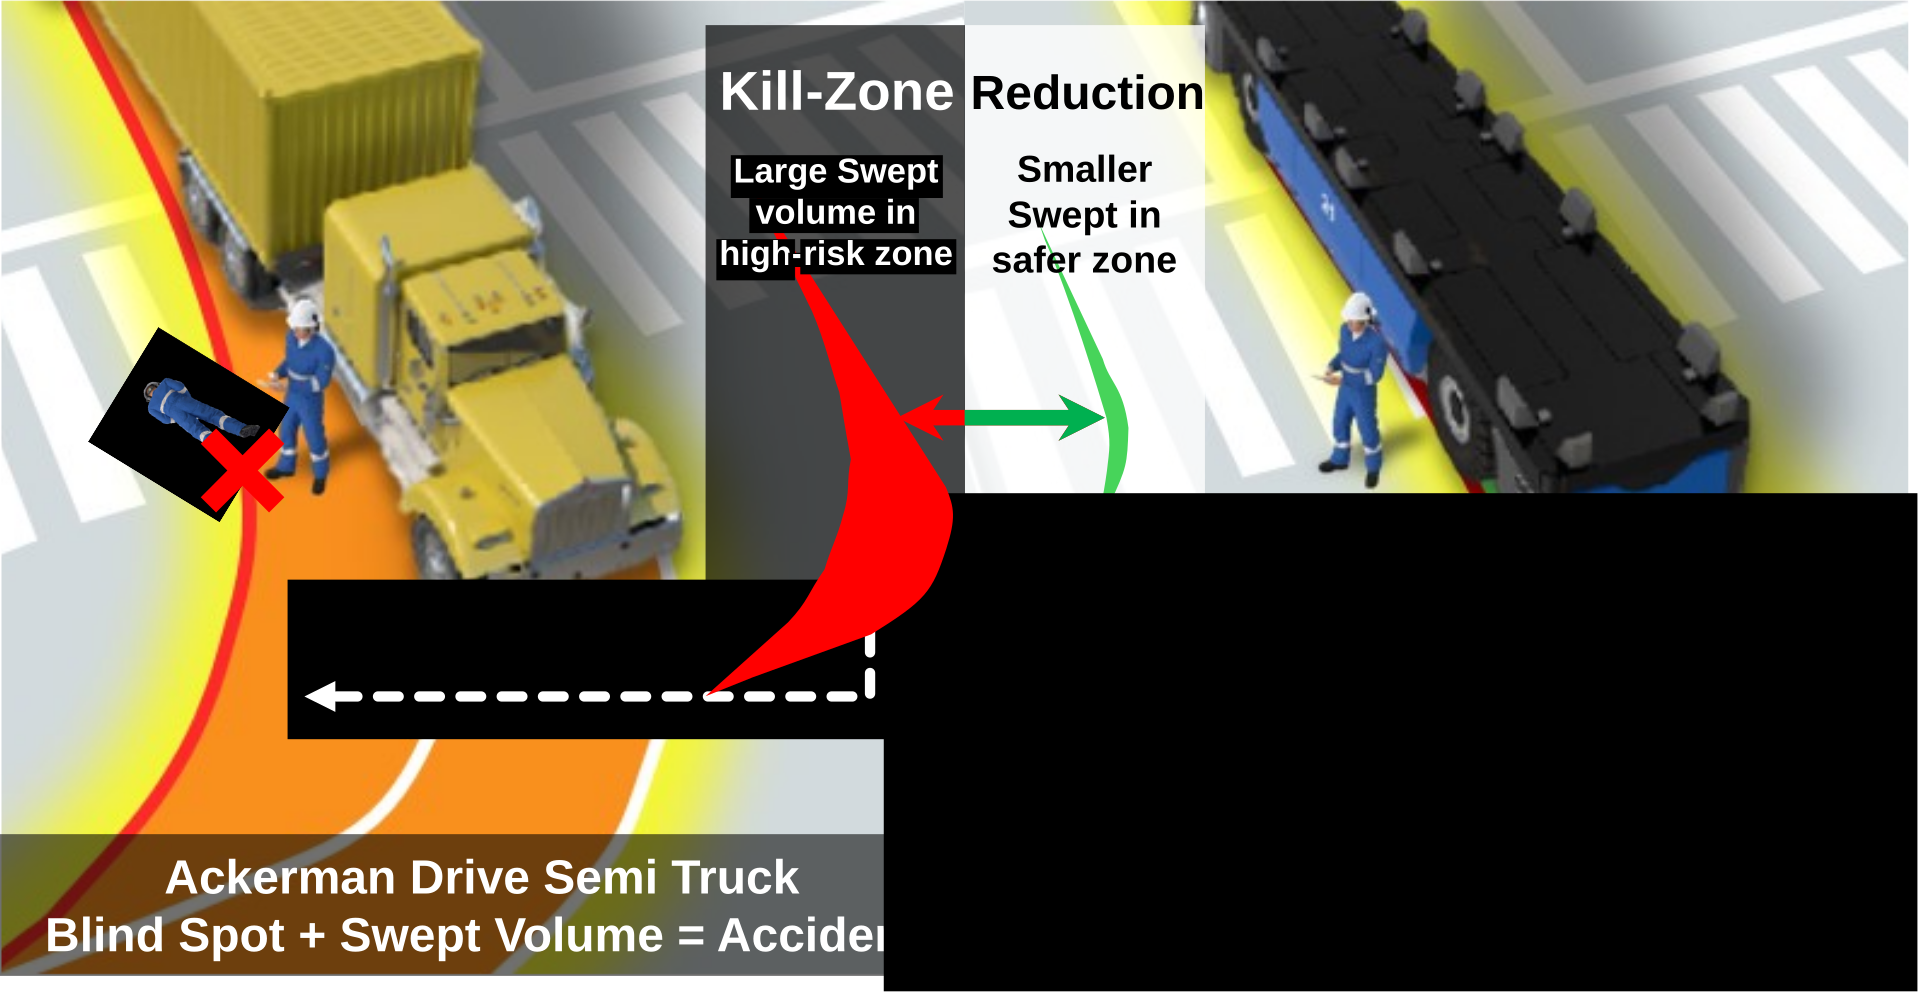
Swept volume-aware trajectory planning and mpc tracking for multi-axle swerve-drive amrs
Accepted by IEEE International Conference on Robotics and Automation (ICRA) , May 2025
First author
Tianxin Hu, Shenghai Yuan, Ruofei Bai, Xinhang Xu, Yuwen Liao, Fen Liu, Lihua Xie
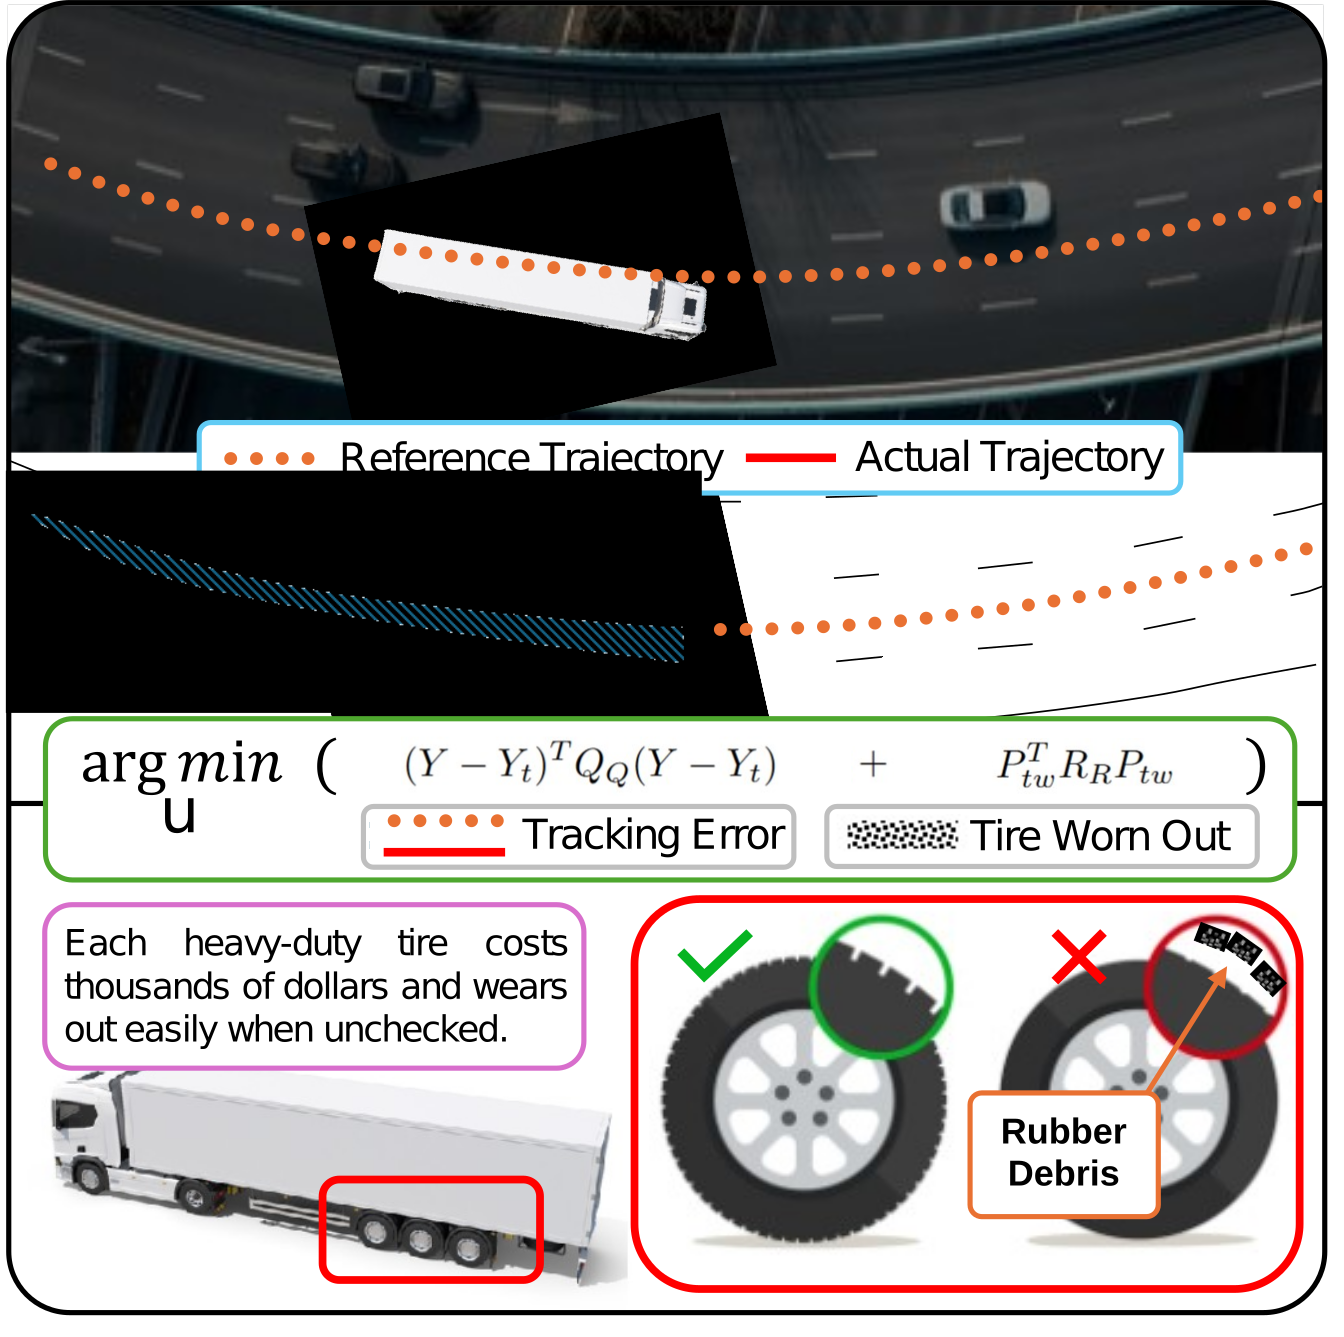
Tire wear aware trajectory tracking control for Multi-axle Swerve-drive Autonomous Mobile Robots
Accepted by Journal of Automation and Intelligence (JAI) , June 2025
first author
Tianxin Hu, Xinhang Xu, Thien-Minh Nguyen, Fen Liu, Shenghai Yuan, Lihua Xie
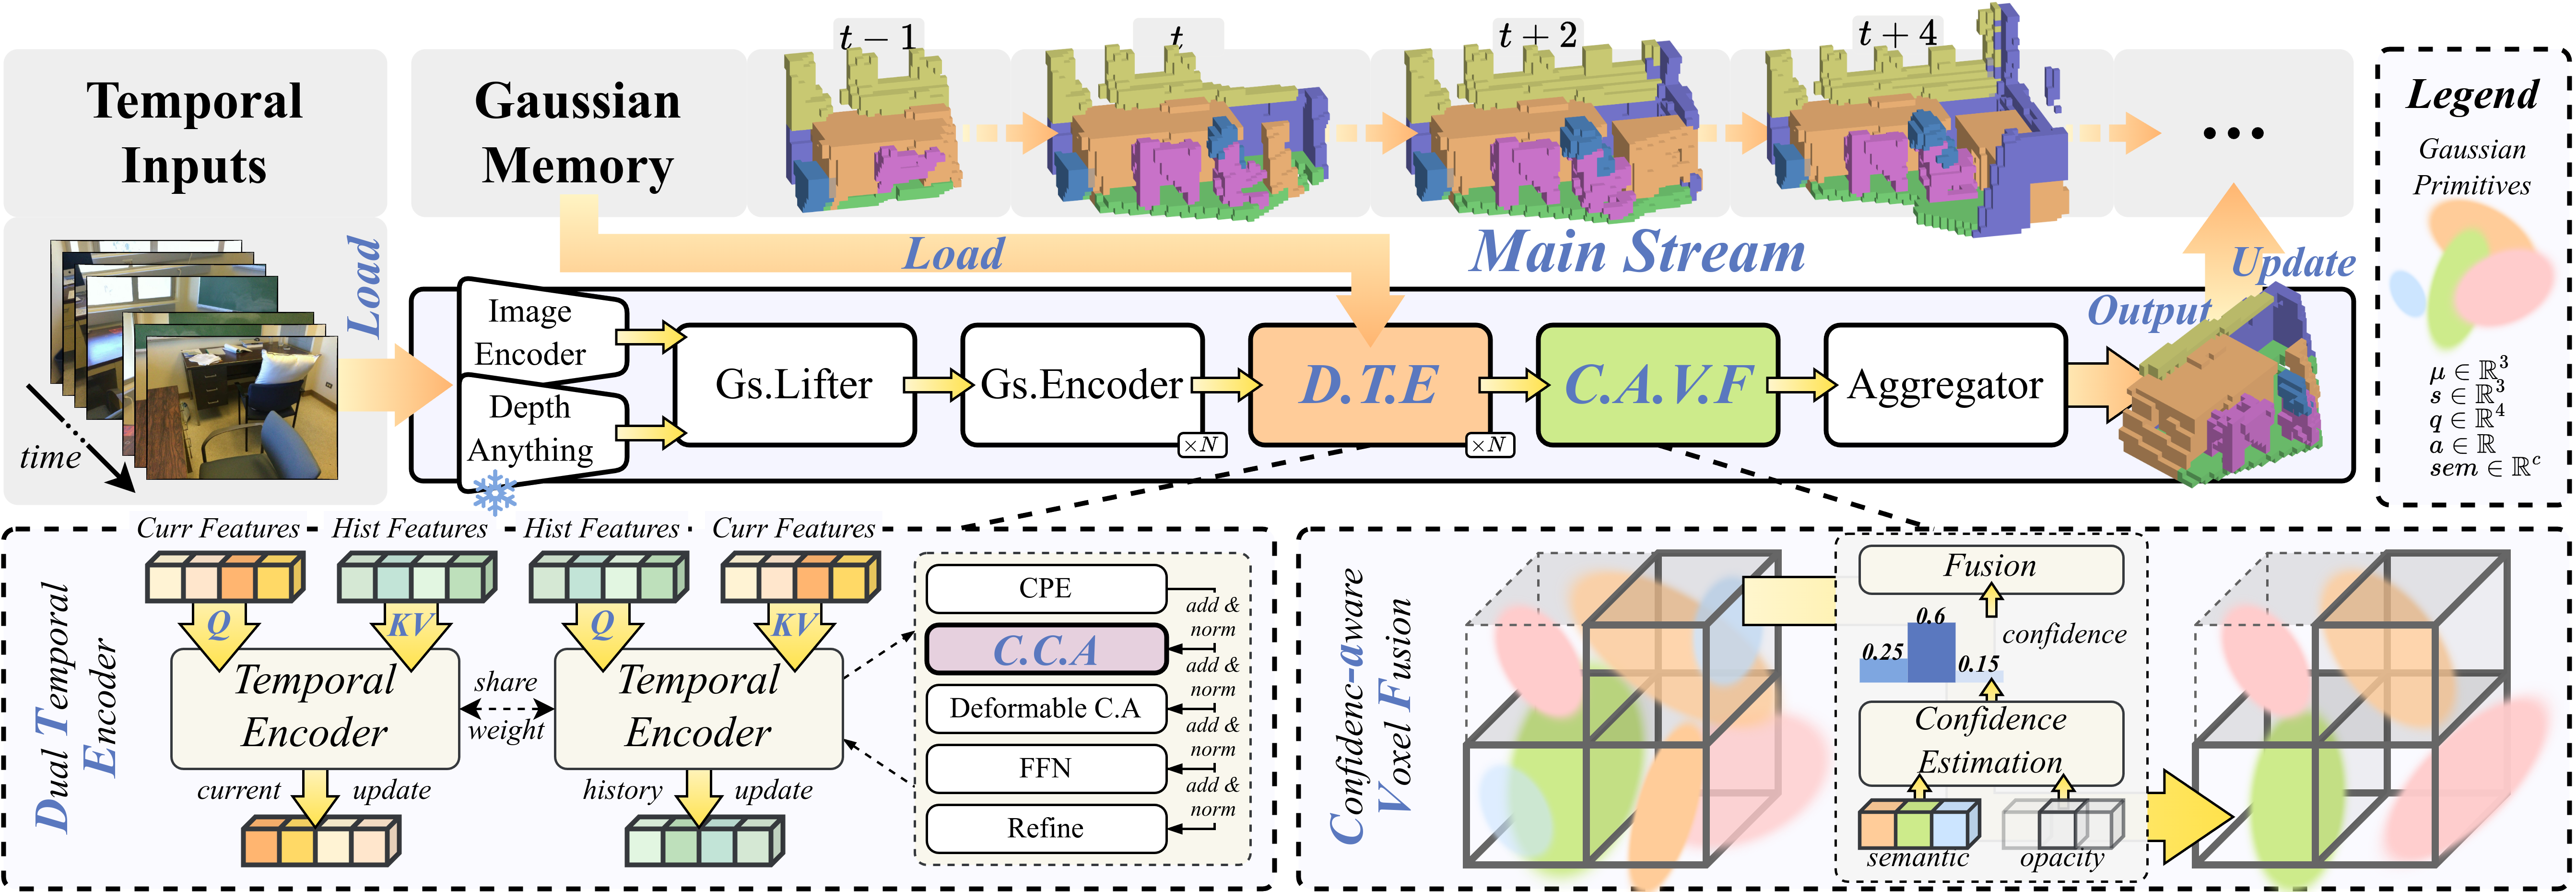
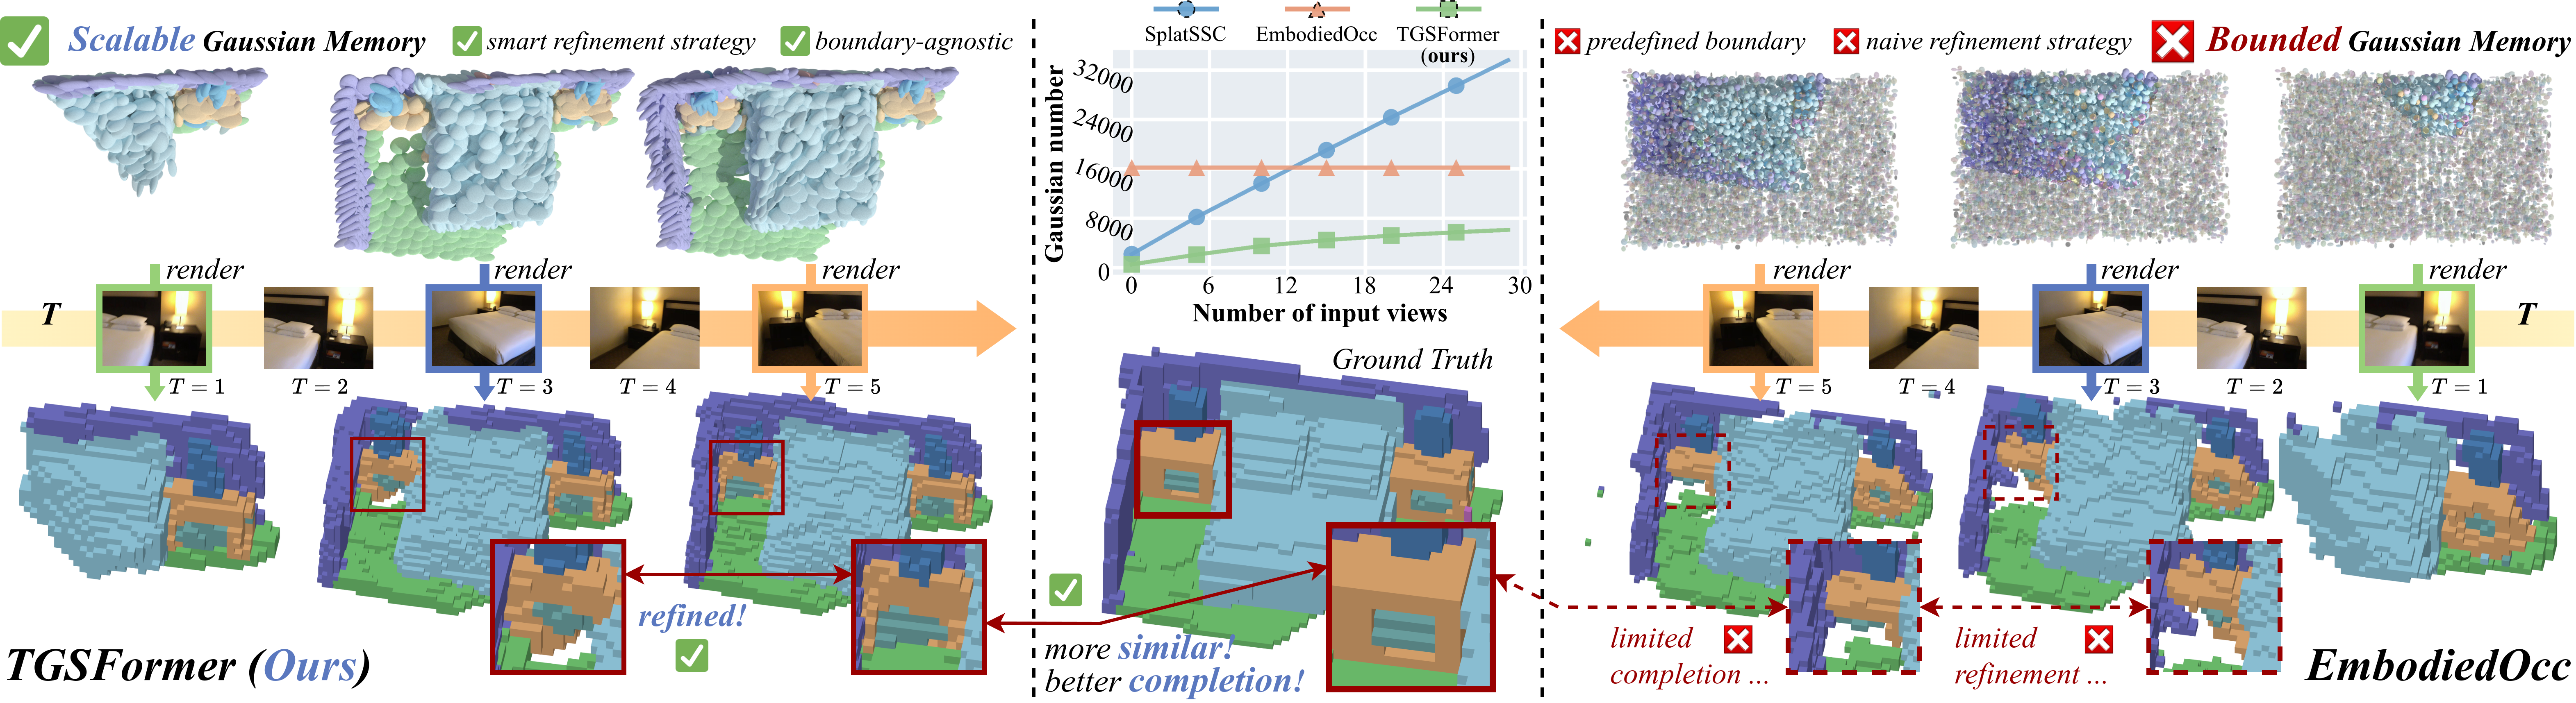
TGSFormer: Scalable Temporal Gaussian Splatting for Embodied Semantic Scene Completion
Accepted by IEEE Conference on Computer Vision and Pattern Recognition(CVPR) , March 2026
Co-author
Rui Qian*, Haozhi Cao*, Tianchen Deng*, Tianxin Hu, Weixiang Guo, Shenghai Yuan, Lihua Xie
🤖 Ongoing Explorations
Go2 Extreme Parkour Extension — Faster Training and More Stable, Natural Locomotion
Building on Extreme Parkour [1], I extended the locomotion training pipeline for the Unitree Go2 with a focus on stability, training efficiency, and more natural gait behaviour.
① More robust adaptation
Expanded the RMA latent representation to retain richer terrain and dynamics context, improving policy stability during challenging parkour manoeuvres.
② 3.5× faster training
Replaced complex mesh-based training terrain with lightweight box primitives, increasing training throughput by approximately 3.5×.
Parkour policy evaluation in Isaac Sim
Sim-to-real deployment on the Unitree Go2
Together, these changes make the training pipeline substantially more efficient while improving the stability and motion quality of the resulting parkour policy in both simulation and real-world deployment.
Reference
[1] Extreme Parkour with Legged Robots
Xuxin Cheng, Kexin Shi, Ananye Agarwal & Deepak Pathak · IEEE International Conference on Robotics and Automation (ICRA), 2024
📜 Patents
[P1] (Granted)
Multi-axle all-wheel steering vehicle vector-division correction method and system
Sep 2025
Tianxian Hu, Xiangrong You, Dongmei Wang, Xinhe Long, Xinyu Wang, Shuang Liu, Yutong Fu, Xinyao Wang, Lefeng Wei, Baizhen Zhang
Patent No.: CN116534005B
[P2] (Granted)
A system and method for automatically correcting the deviation of a beam transport vehicle in a tunnel
Jul 2023
Xiangrong You, Enze Jin, Dongmei Wang, Yuran Huang, Tianxian Hu, Shuai Zhu, Beijia Zhang
Patent No.: CN114633801B
[P3] (Pending)
Energy-saving system and method for beam transport vehicle based on traveling pressure control
Feb 2024
Wei Li, Xiangrong You, Dongmei Wang, Xinhe Wang, Peng Cheng, Yuming Liu, Shuang Hu, Tianxian Hu, Xinyao Wang, Lefeng Wei, Baizhen Zhang
Application No.: CN117508238A
[P4] (Pending)
Method, system and equipment for planning obstacle avoidance path of multi-shaft all-wheel steering beam transporting vehicle
Dec 2023
Xiangrong You, Yucheng Yin, Liwei Wang, Dongmei Wang, Tianxian Hu, Shuang Liu, Xinyao Wang, Lefeng Wei, Baizhen Zhang
Application No.: CN117168481A
🚀 Projects
💼 Professional Projects
AIBOT Technology Pte. Ltd. — Autonomous Navigation System Development
Supervisor: Professor Lihua Xie, Dr. Shenghai Yuan
Position: Navigation Module Lead
Jul 2025 - Jun 2026
- Responsibilities: Developed the full-stack navigation module for the company’s autonomous mobile robot, covering cross-floor navigation, and dynamic obstacle avoidance in residential and commercial environments.
- Achievements: Achieved fully autonomous navigation and delivery within multi-story residential complexes.
Xin Chi Technology — Research and Development of Autonomous Driving System for Multi-Axle Heavy-Duty Transport Vehicles
Supervisor: Senior Engineer Xiangrong You
Position: Technical Director & Corporate Legal Representative
Jun 2022 - Jun 2024
WUST-CHIJI Formula Racing Team Development
Supervisors: Associate Professor Chao Deng, Dr. Junyi Zou
Position: Leader of the Unmanned Group & Member of Electronic System Group
Feb 2021 - Jun 2024
- Responsibilities: Led the design and implementation of the autonomous system for the Chiji Formula Racing Team, covering detection, mapping, planning, and tracking.
- Achievements: Received the FSAC Third Prize, Best Rookie Award [A7].
🎨 Toy Projects
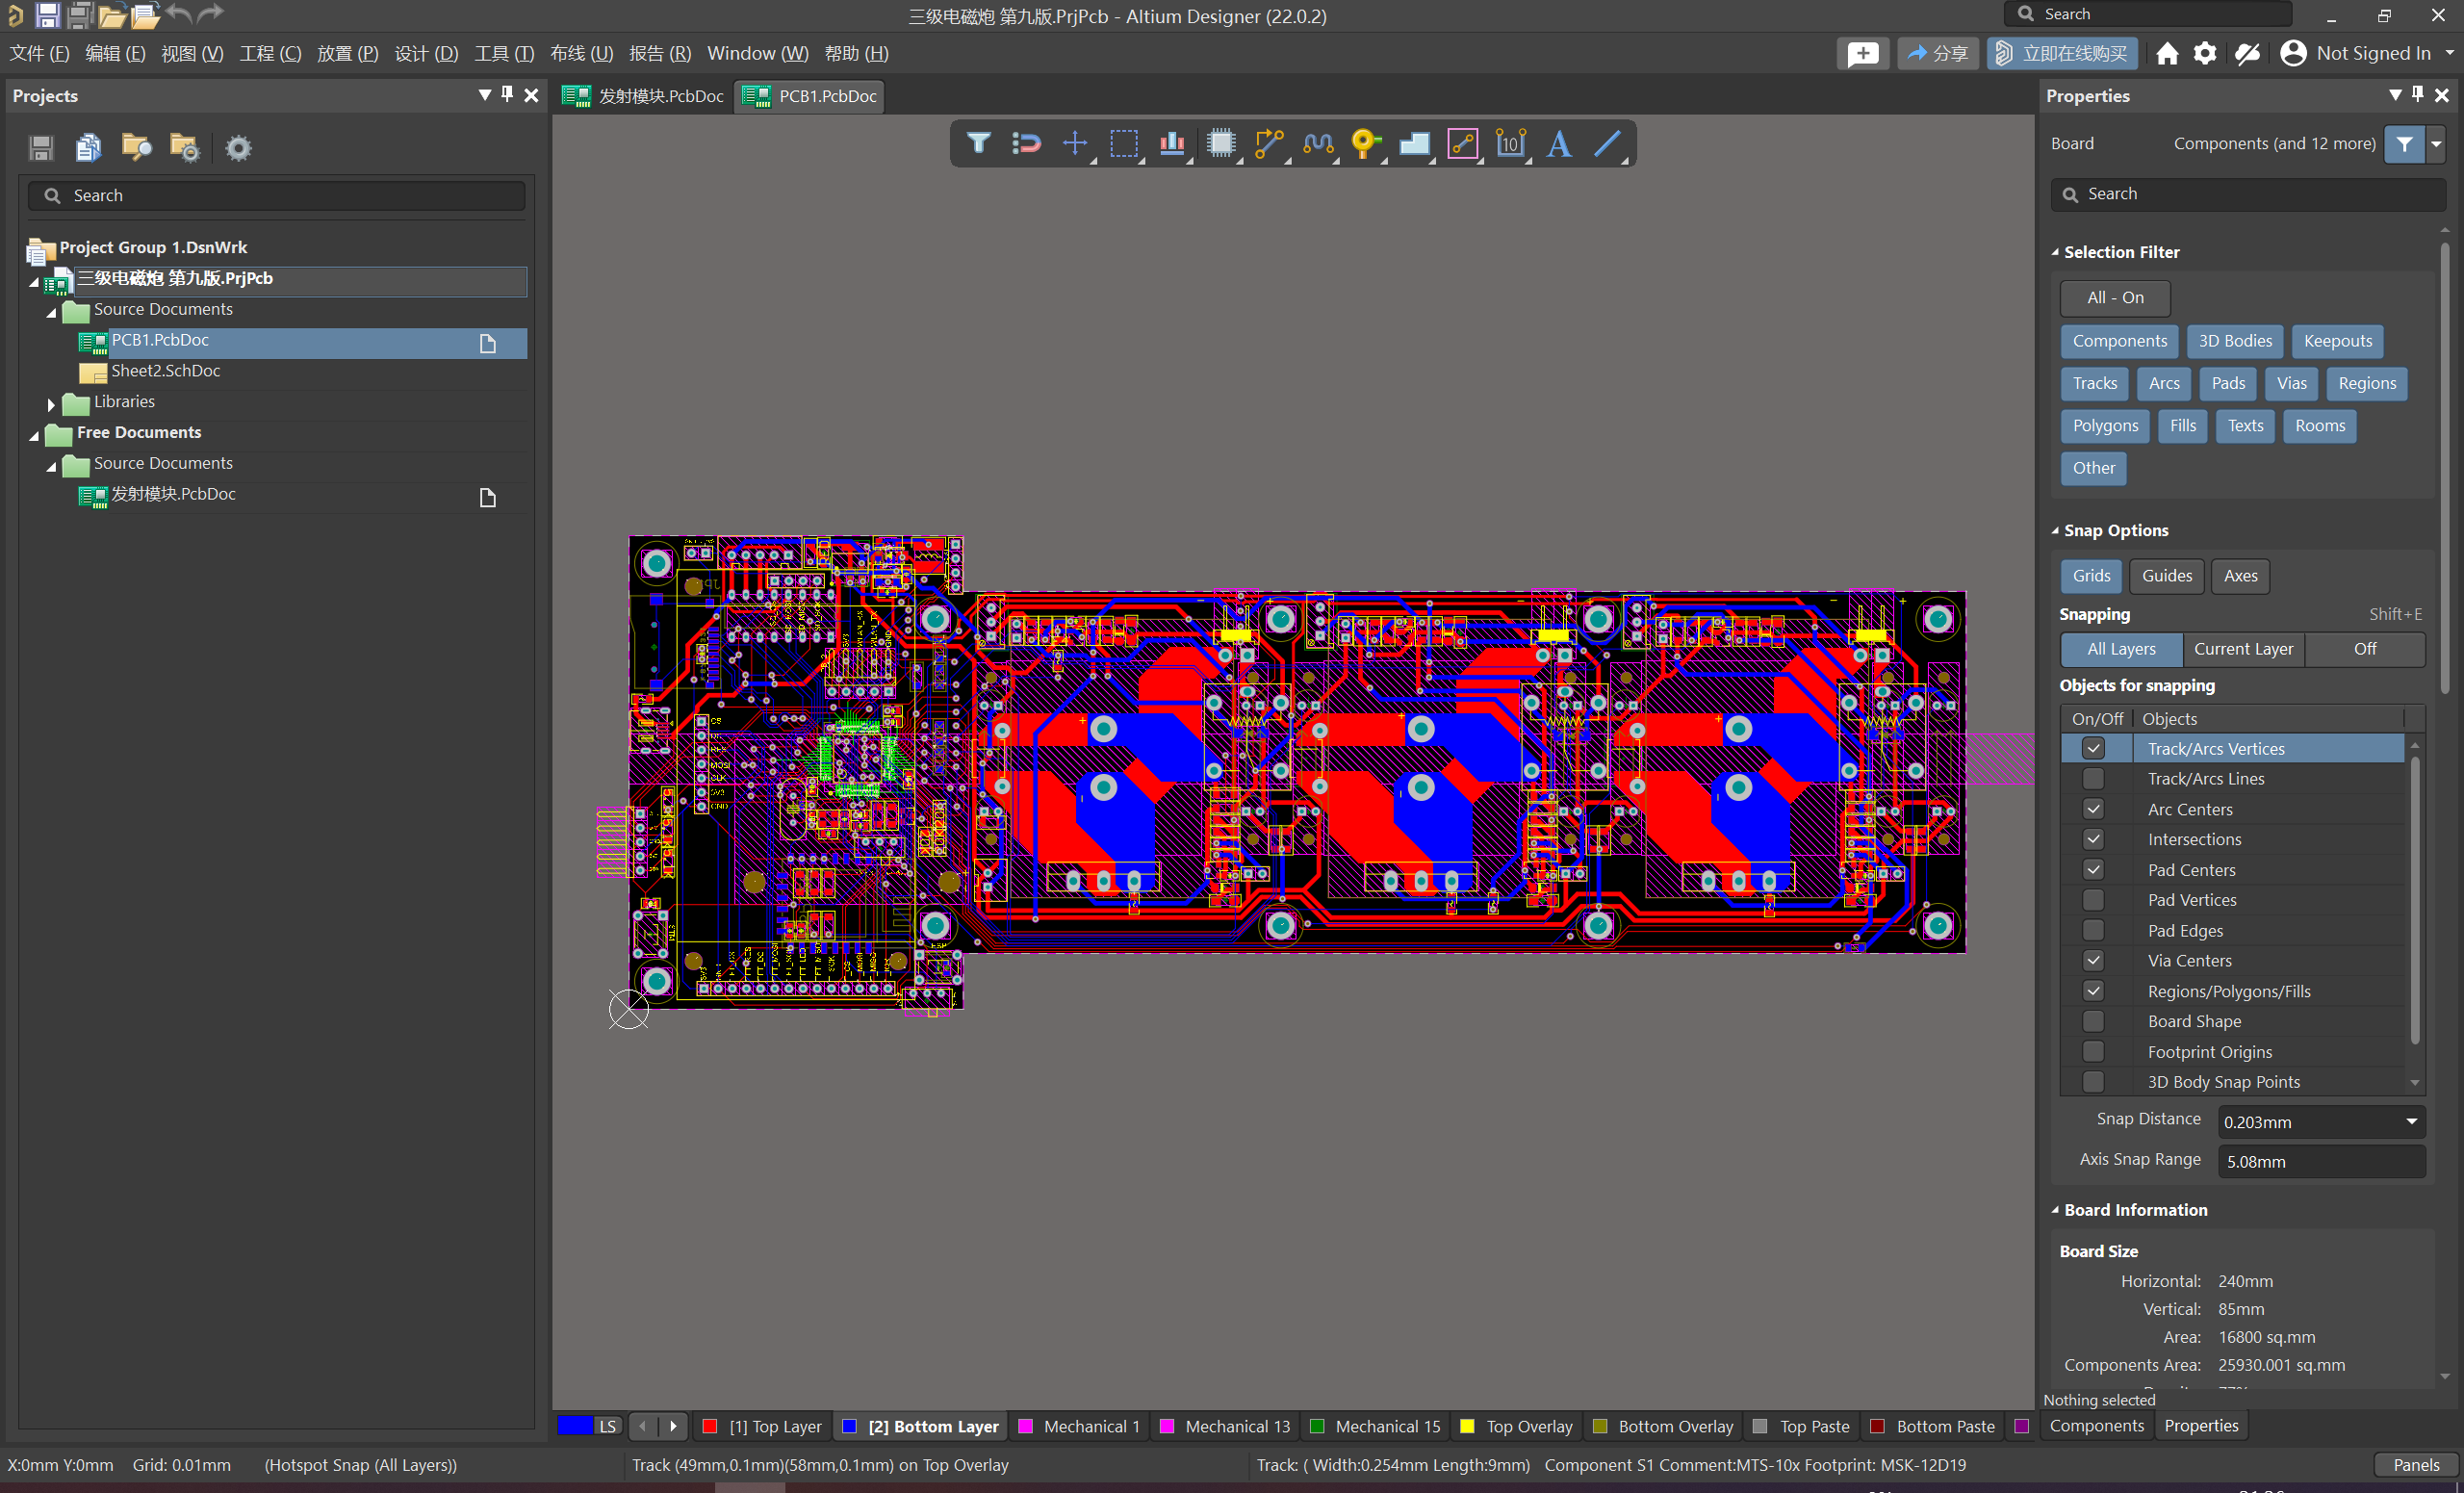
Three-Stage Coilgun PCB Diagram
Three-Stage Coilgun Demonstration
Autonomous Racing Simulation
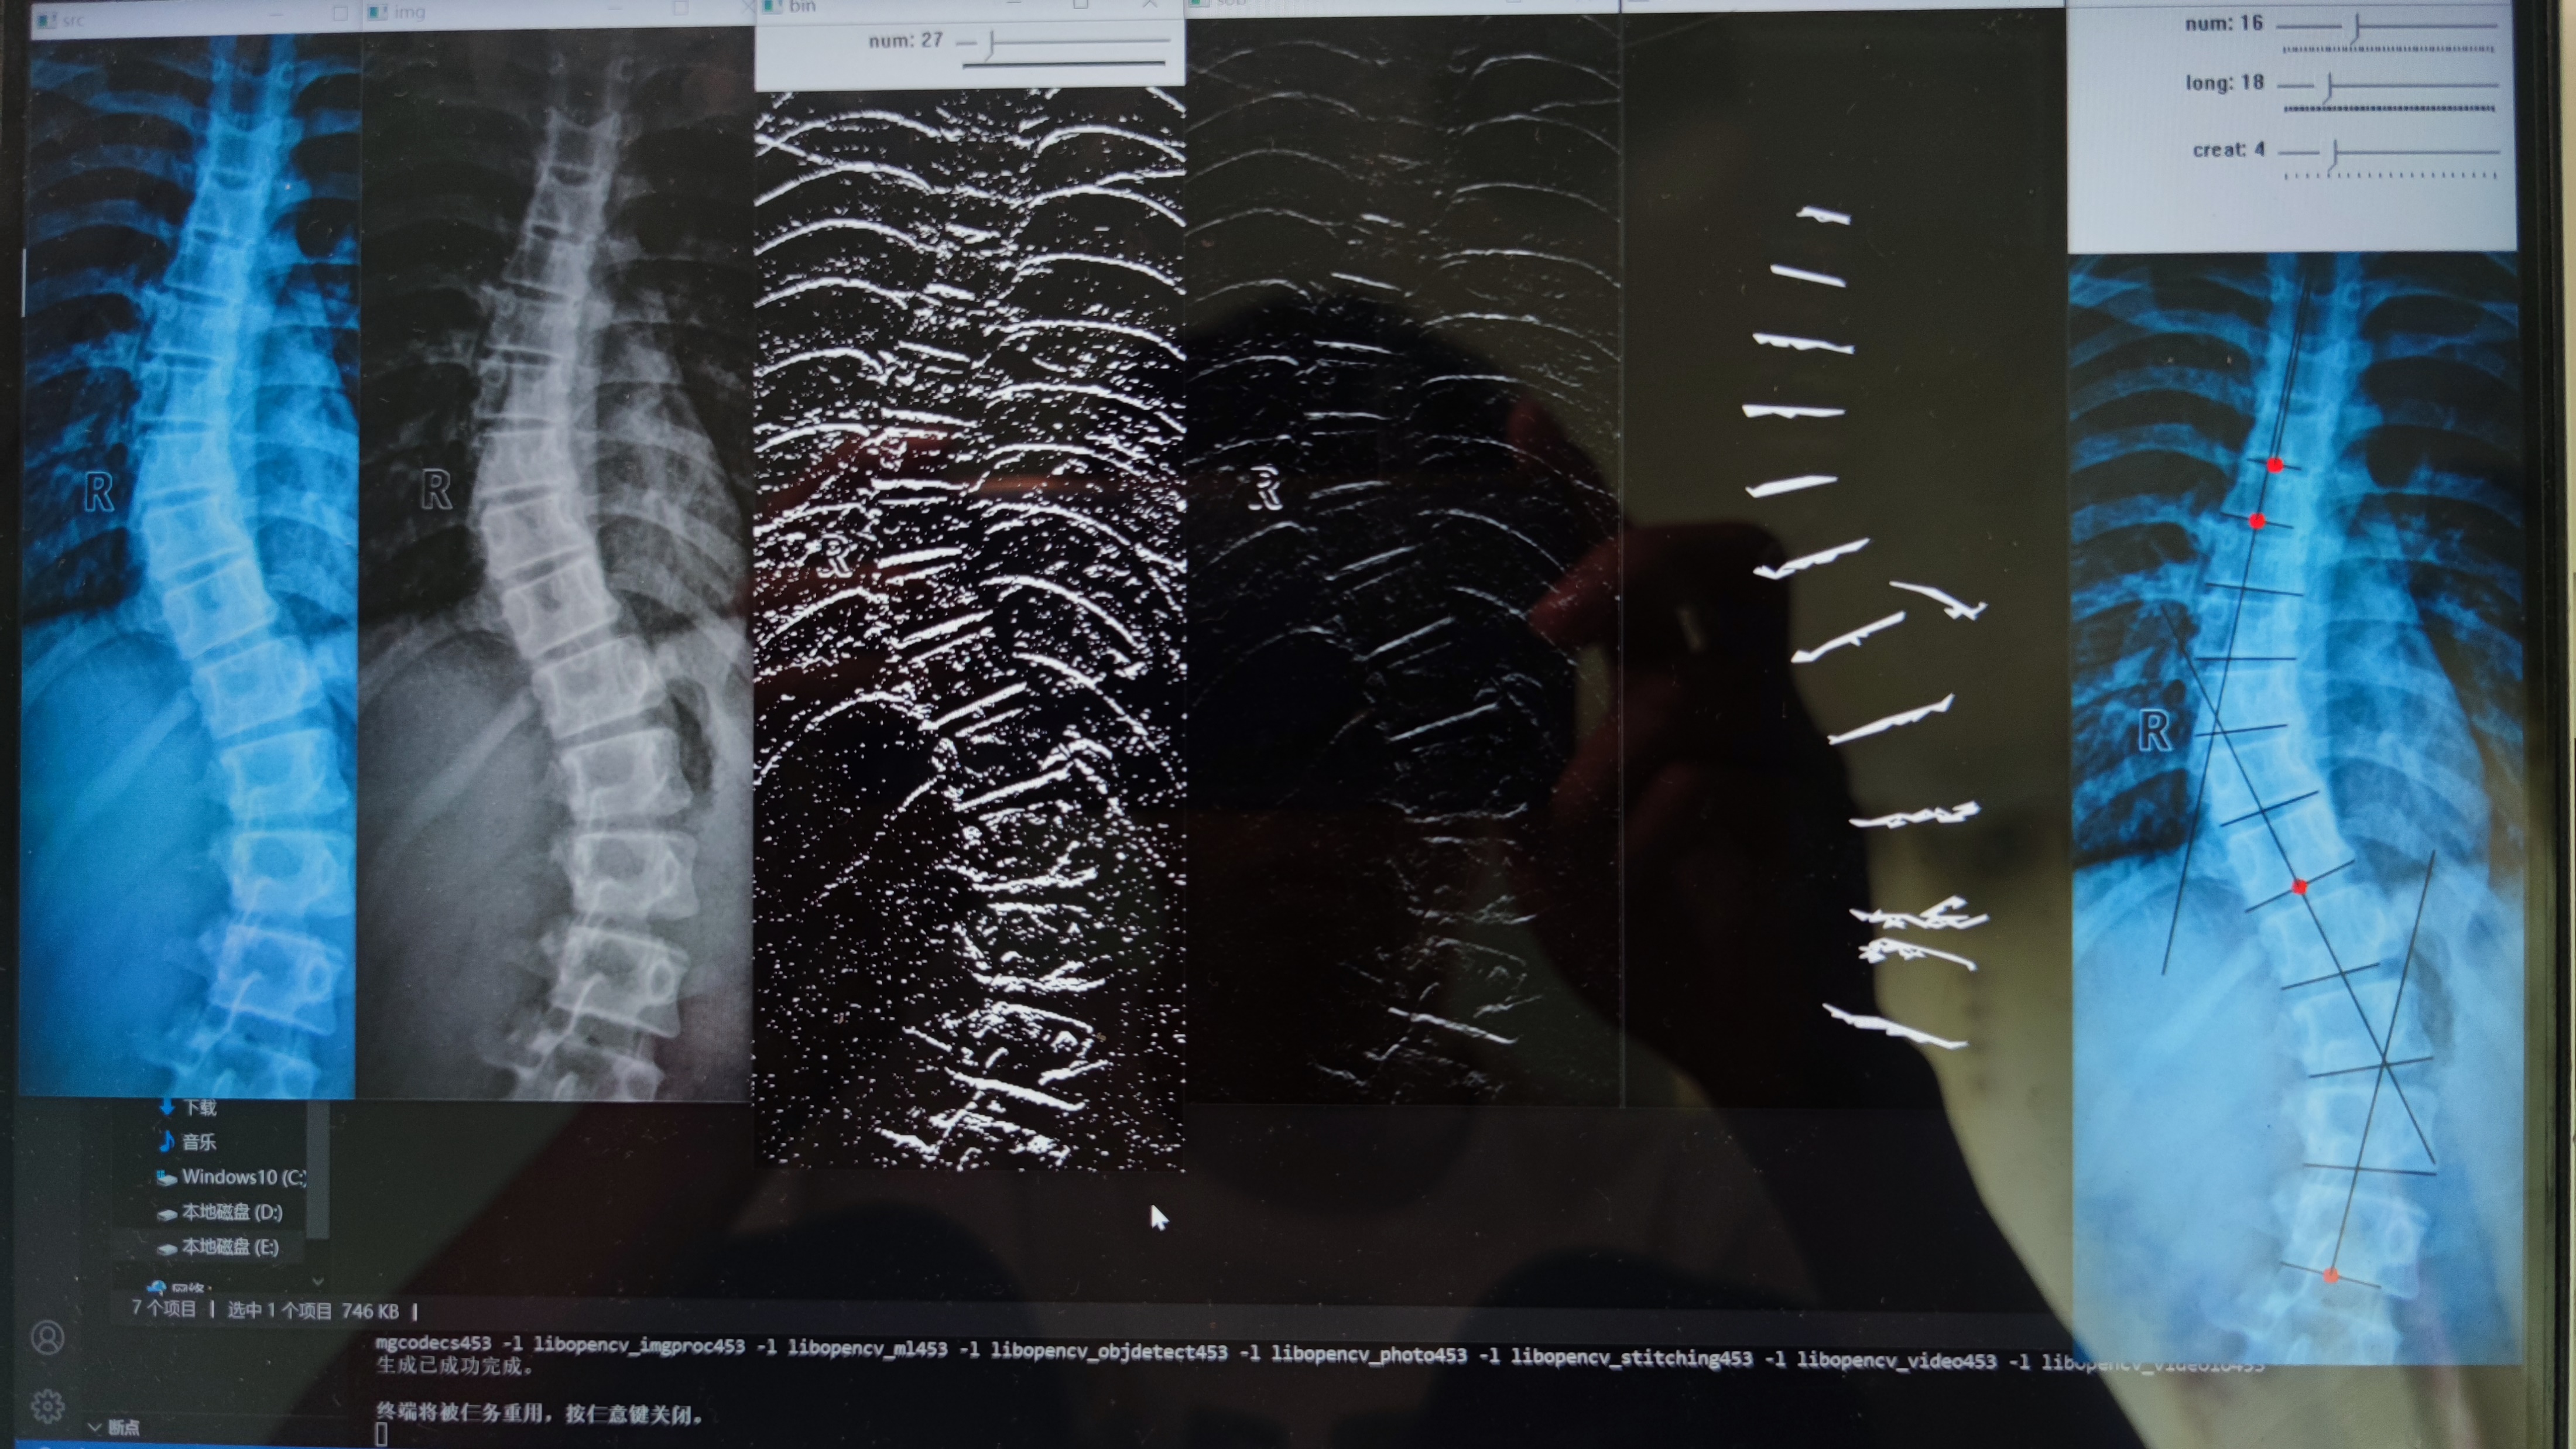
Spinal Curvature Measurement Program
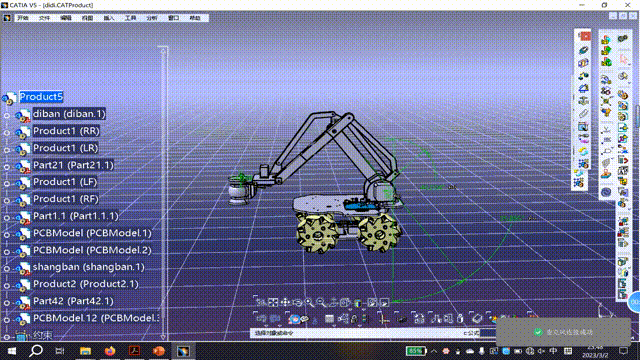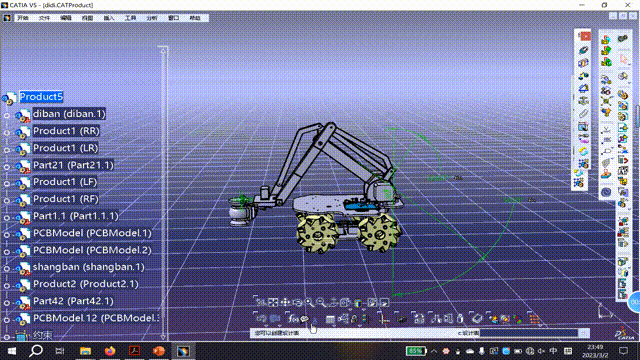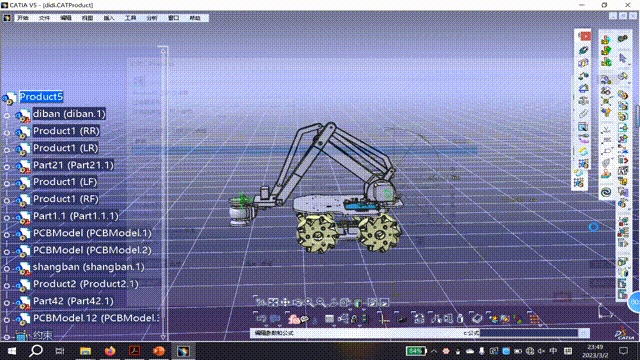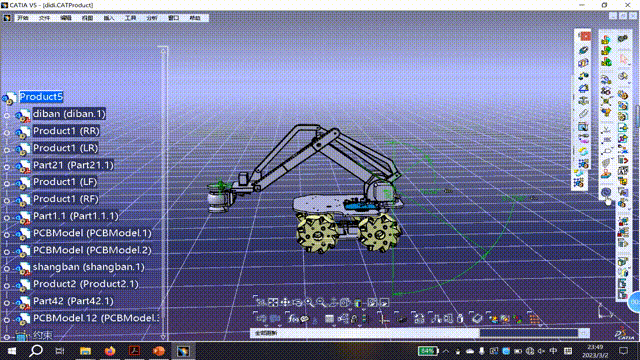
Robotic Arm Model-Based Control Simulation
Material Handling Demonstration
🎖 Honors and Awards
[A1] (International Level)
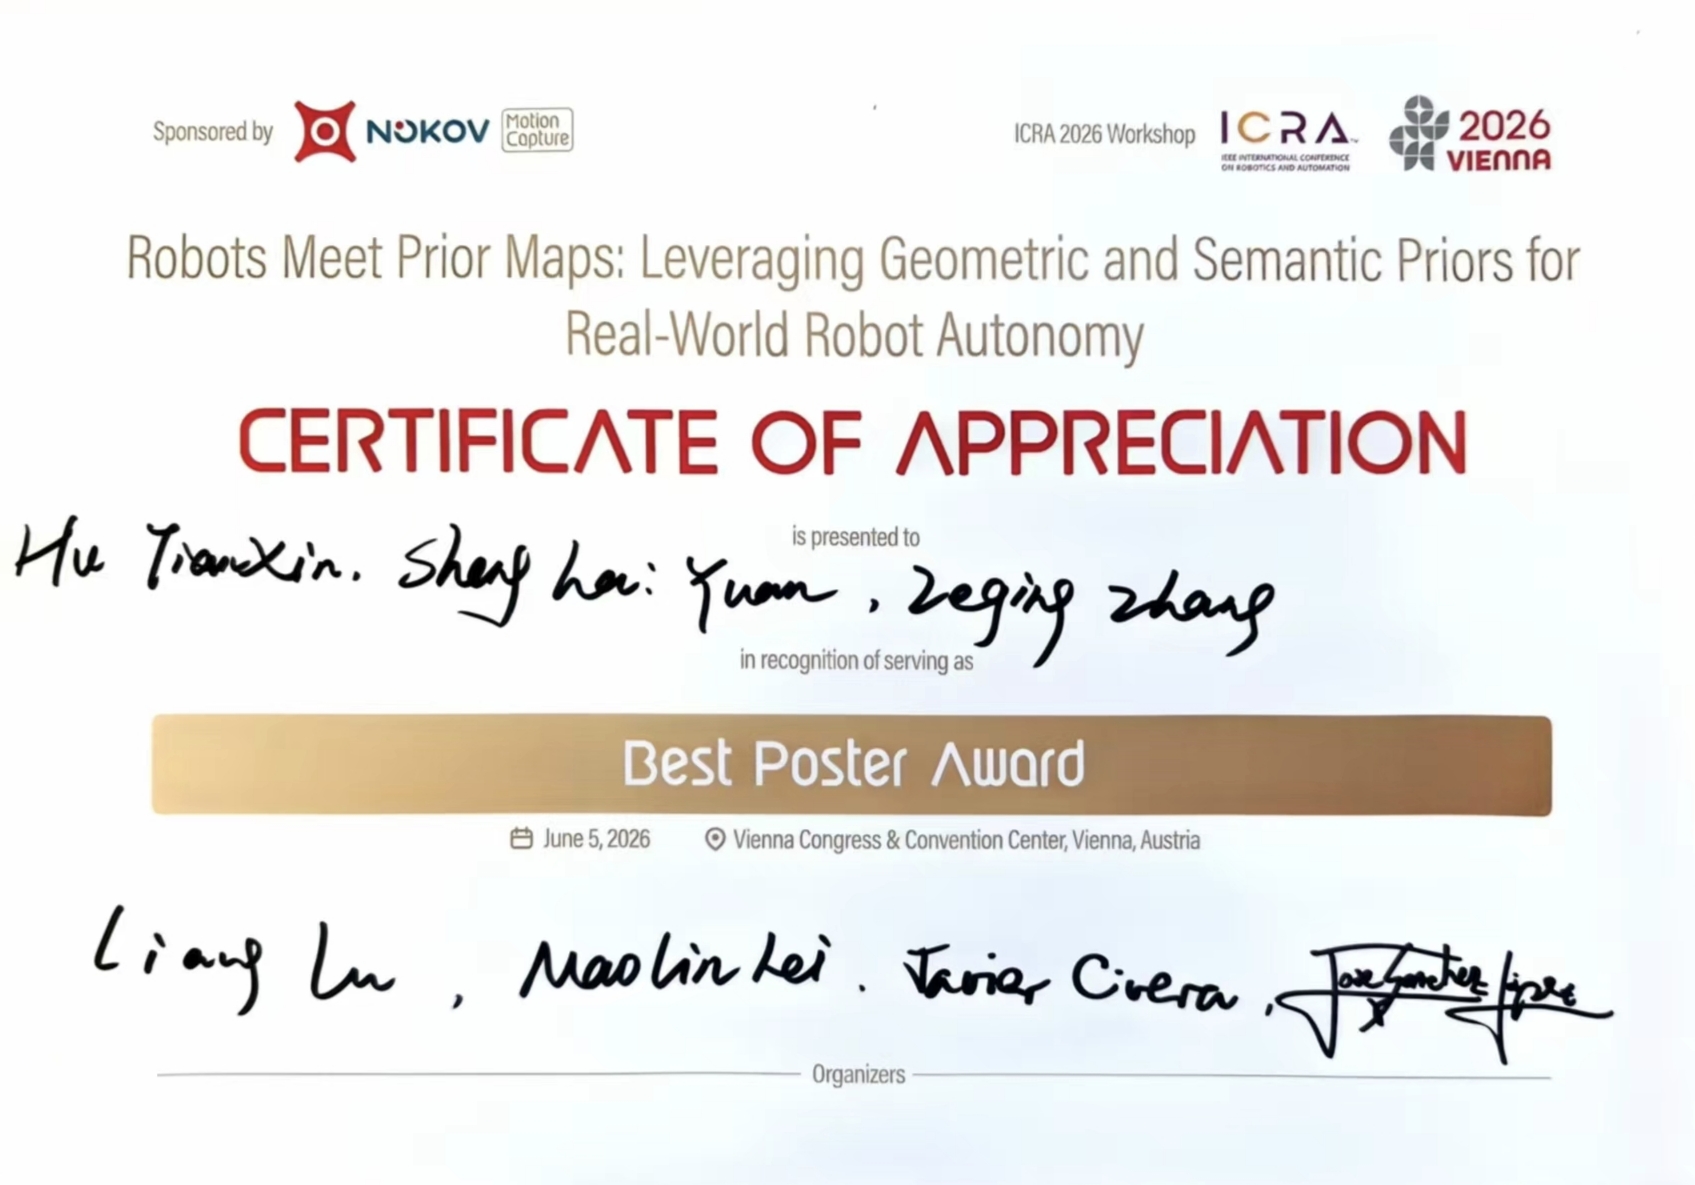
Best Poster Award — ICRA 2026 Workshop
Jun 2026
Robots Meet Prior Maps: Leveraging Geometric and Semantic Priors for Real-World Robot Autonomy · Vienna, Austria
[A2] (International Level)
Bronze Award of the 9th China International College Students Innovation Competition
Apr 2024
Organizing Committee of China College Students "Internet+" Competition
[A3] (National Level)
The First Prize of the 18th "Challenge Cup" National Undergraduate Curricular Academic Science and Technology Works
Oct 2023
China Association for Science and Technology, Ministry of Education of the PRC, Chinese Academy of Social Sciences
[A4] (International Level)
Bronze Award of the 8th China College Students "Internet+" Innovation and Entrepreneurship Competition
Apr 2023
Organizing Committee of China College Students "Internet+" Competition
[A5] (National Level)
Second Prize of the 15th China College Student Computer Design Competition
Jul 2022
Organizing Committee of Chinese College Student Computer Design Competition
[A6] (National Level)
Second Prize of the 15th Energy Saving and Emission Reduction Competition
Aug 2022
China College Student Energy Conservation and Emission Reduction Social Practice and Technology Competition Committee
[A7] (National Level)
Third Prize and Best Rookie Award of Formula Student Competition
Oct 2022
China Society of Automotive Engineers, Organizing Committee of FSAC